The AR4 build manual, animated in three dimensions.
An unofficial visual companion for building the Annin Robotics AR4, an open-source six-axis robot arm. It follows the AR4 Robot Manual v1.5 step by step, from the J1 base enclosure to the gripper, the wiring and calibration. The manual stays the authority for wiring diagrams, photographs and safety notes.
- Arm
- Annin Robotics AR4 · six axes
- Follows
- AR4 Robot Manual v1.5
- Pages
- 30 · parts list to calibration
- Reach
- 629 mm · payload 1.9 kg
- Built with
- Annin CAD · three.js · one HTML page
The manual

- 01
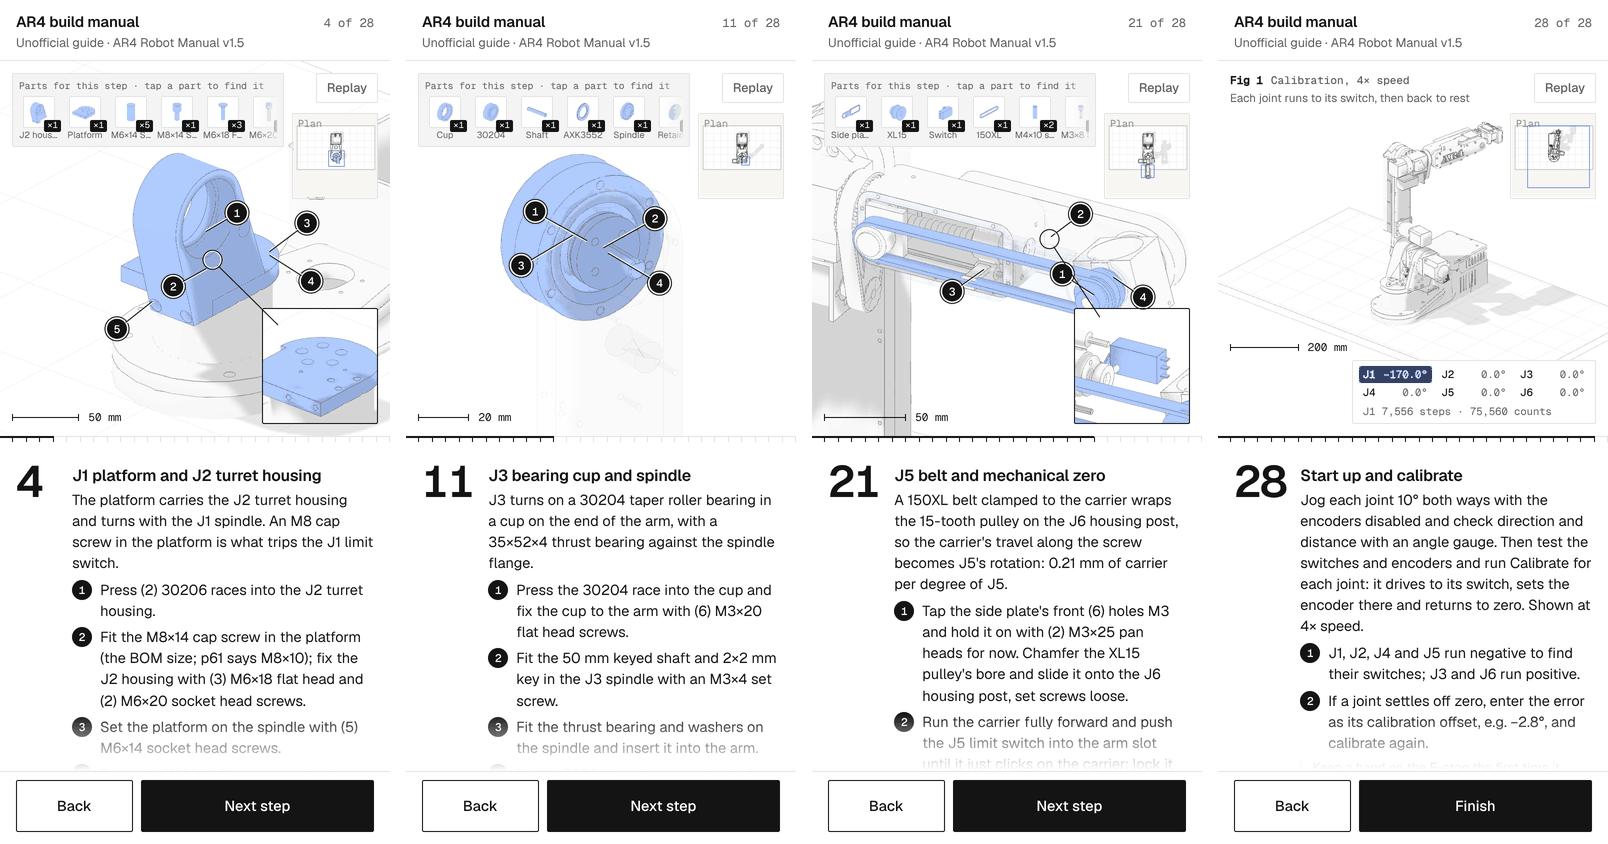
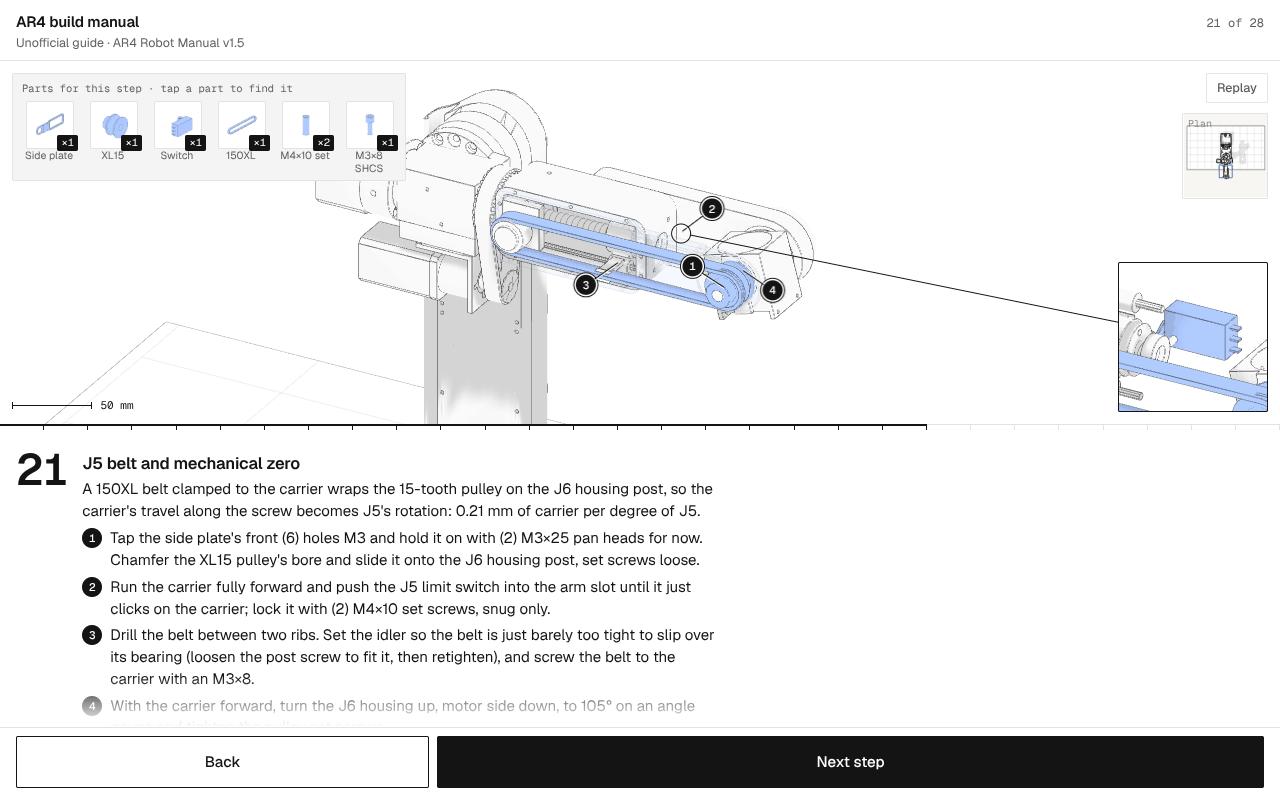
Every step is drawn on Annin's own CAD: parts fly into place and numbered marks point at what each instruction touches.
- 02
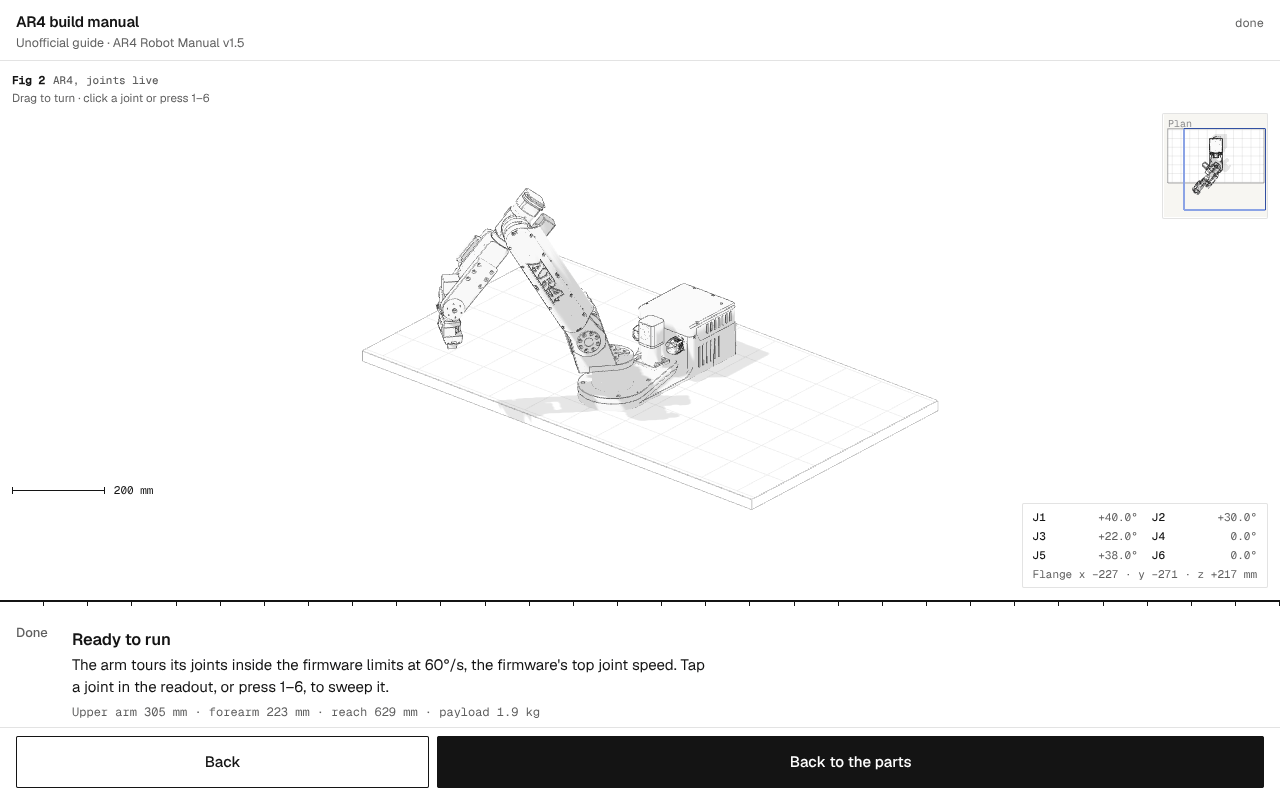
The finished arm moves on the same kinematics, joint limits and motor numbers the firmware uses. Tap a joint to sweep it.
- 03
Calibration runs each joint to its limit switch at 4× speed with live step and encoder counts.
- 04
Phone-first: one 1.6 MB page with a local copy of three.js and no third-party scripts.
The film
On a phone and a desk
Go and look
An independent project, not an Annin Robotics product. Where this page and the manual disagree, follow the manual. The source, the CAD export tools and the licences are on GitHub.